Ethical Attractors in Complex Networks (Paper A)
Archived research code. Simulation substrate for closed-loop monitoring of coarse network observables under partial observability.
What this was
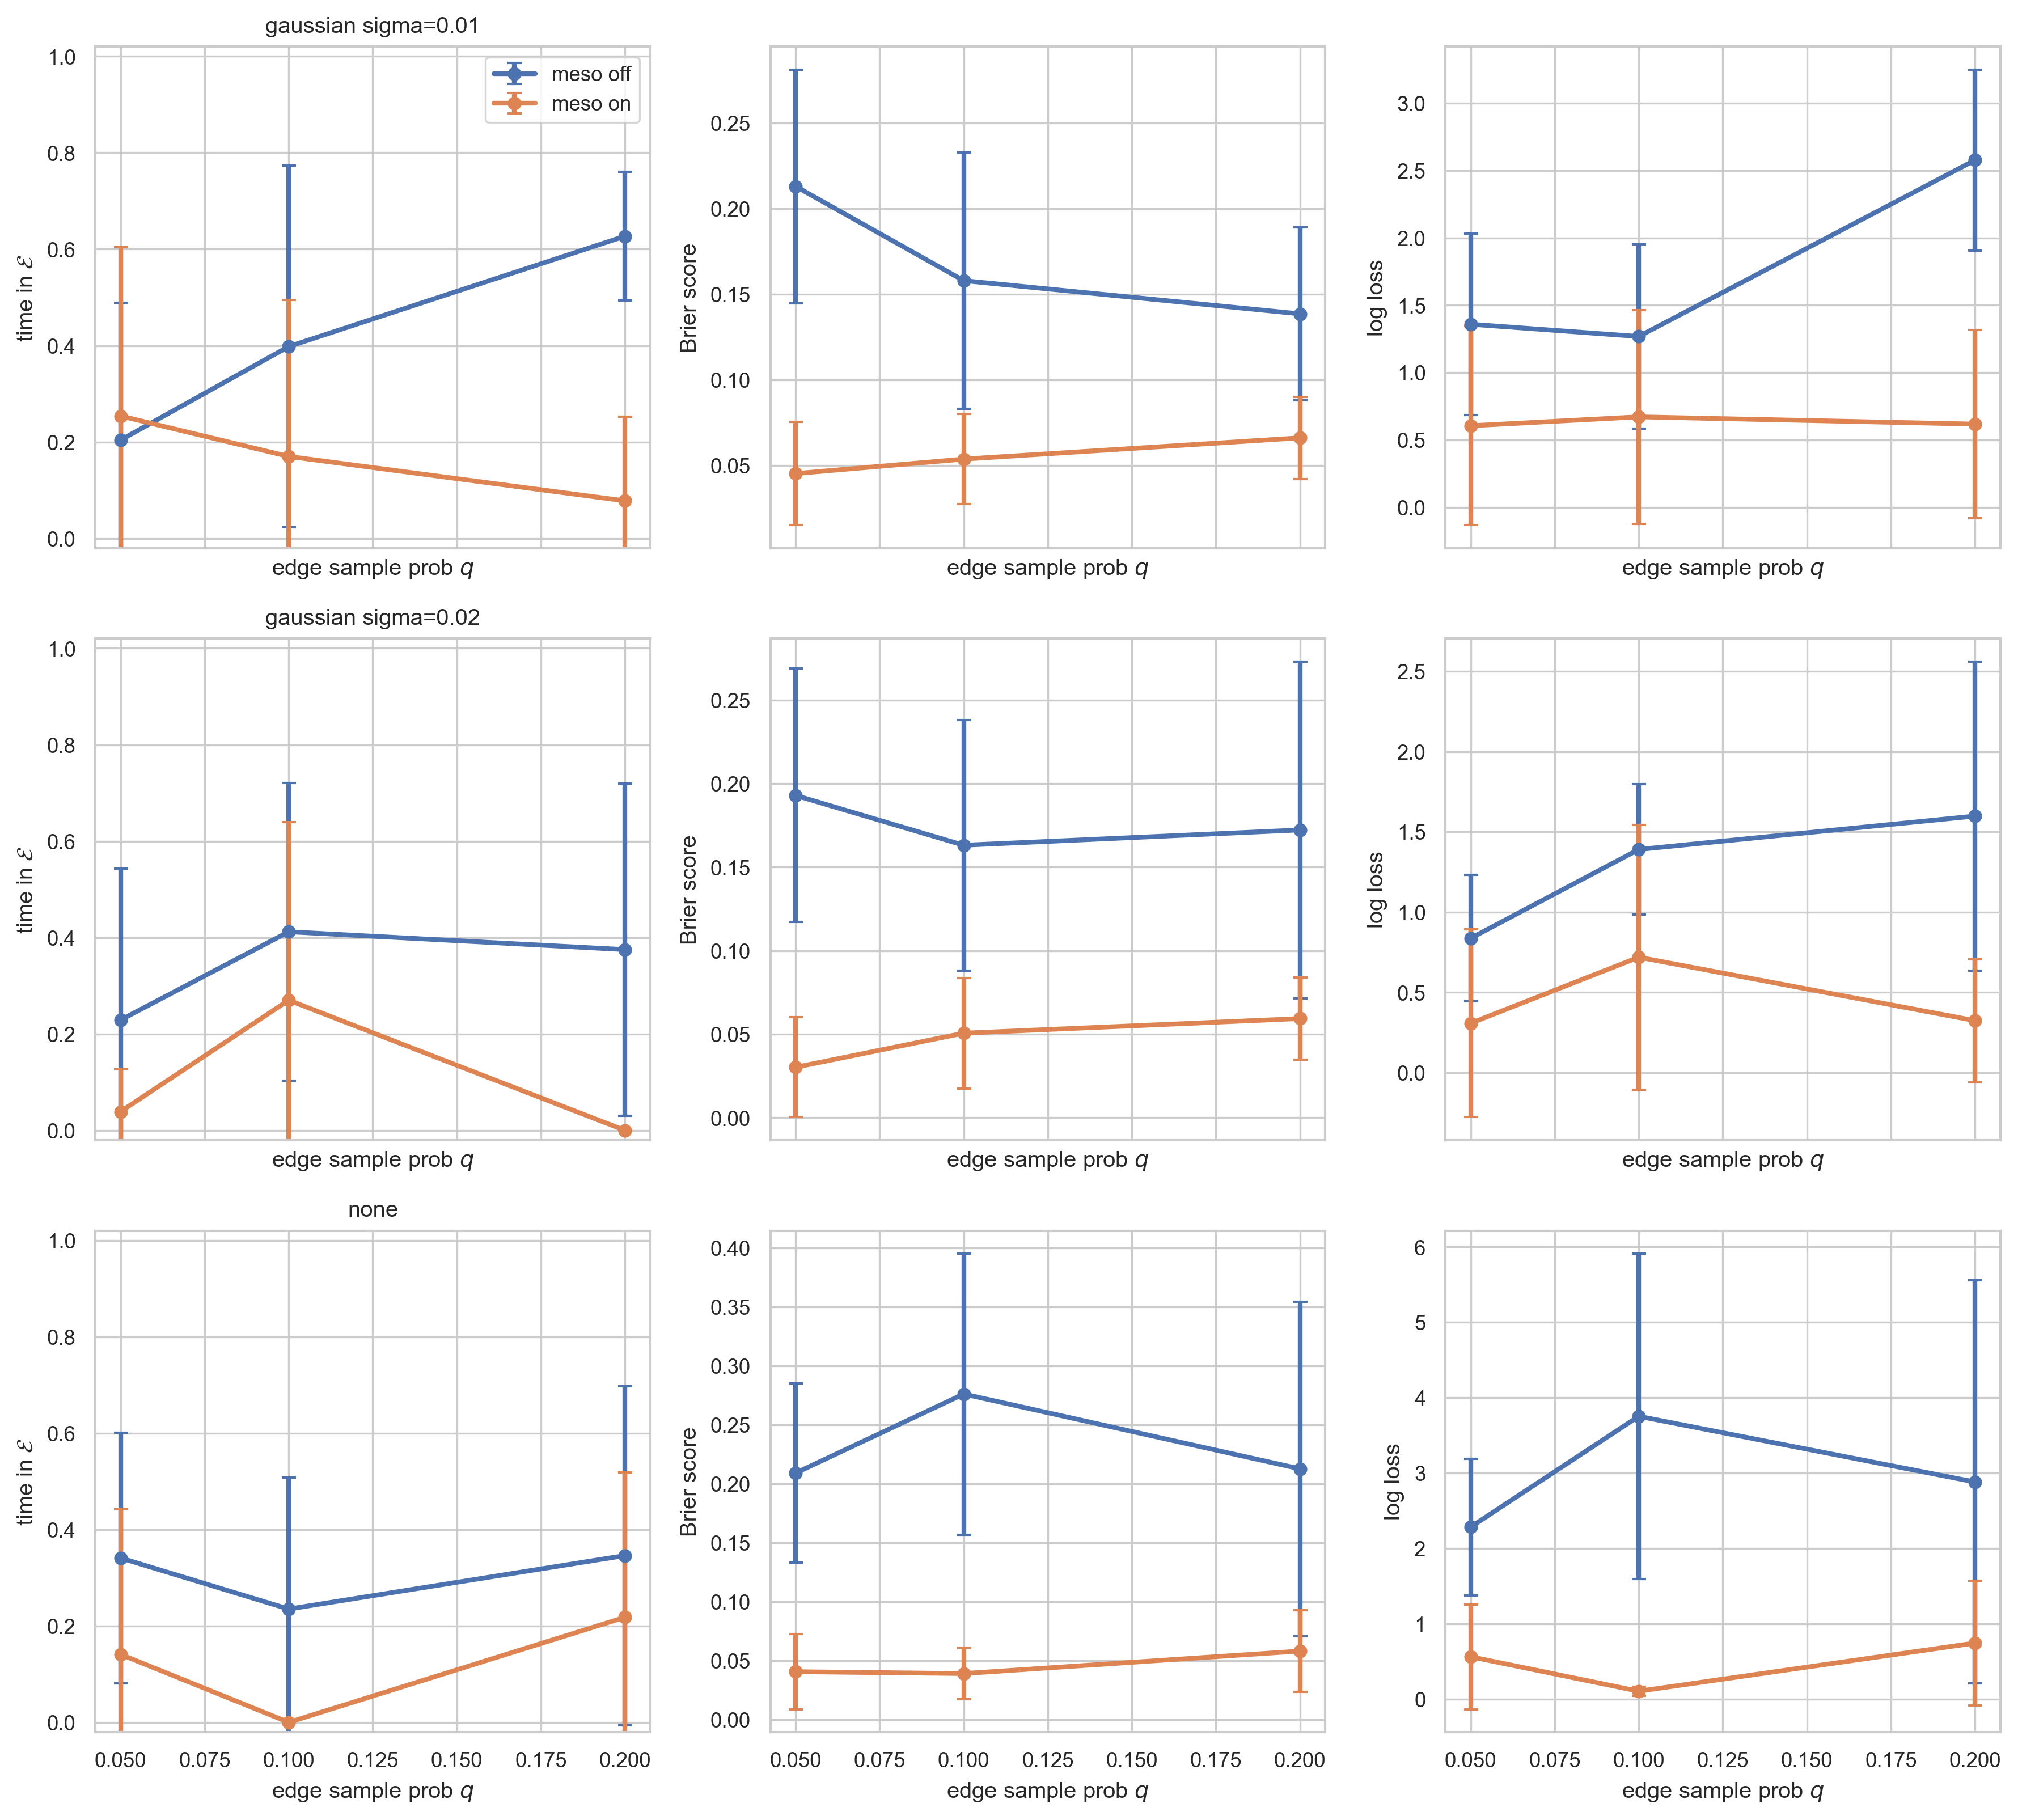
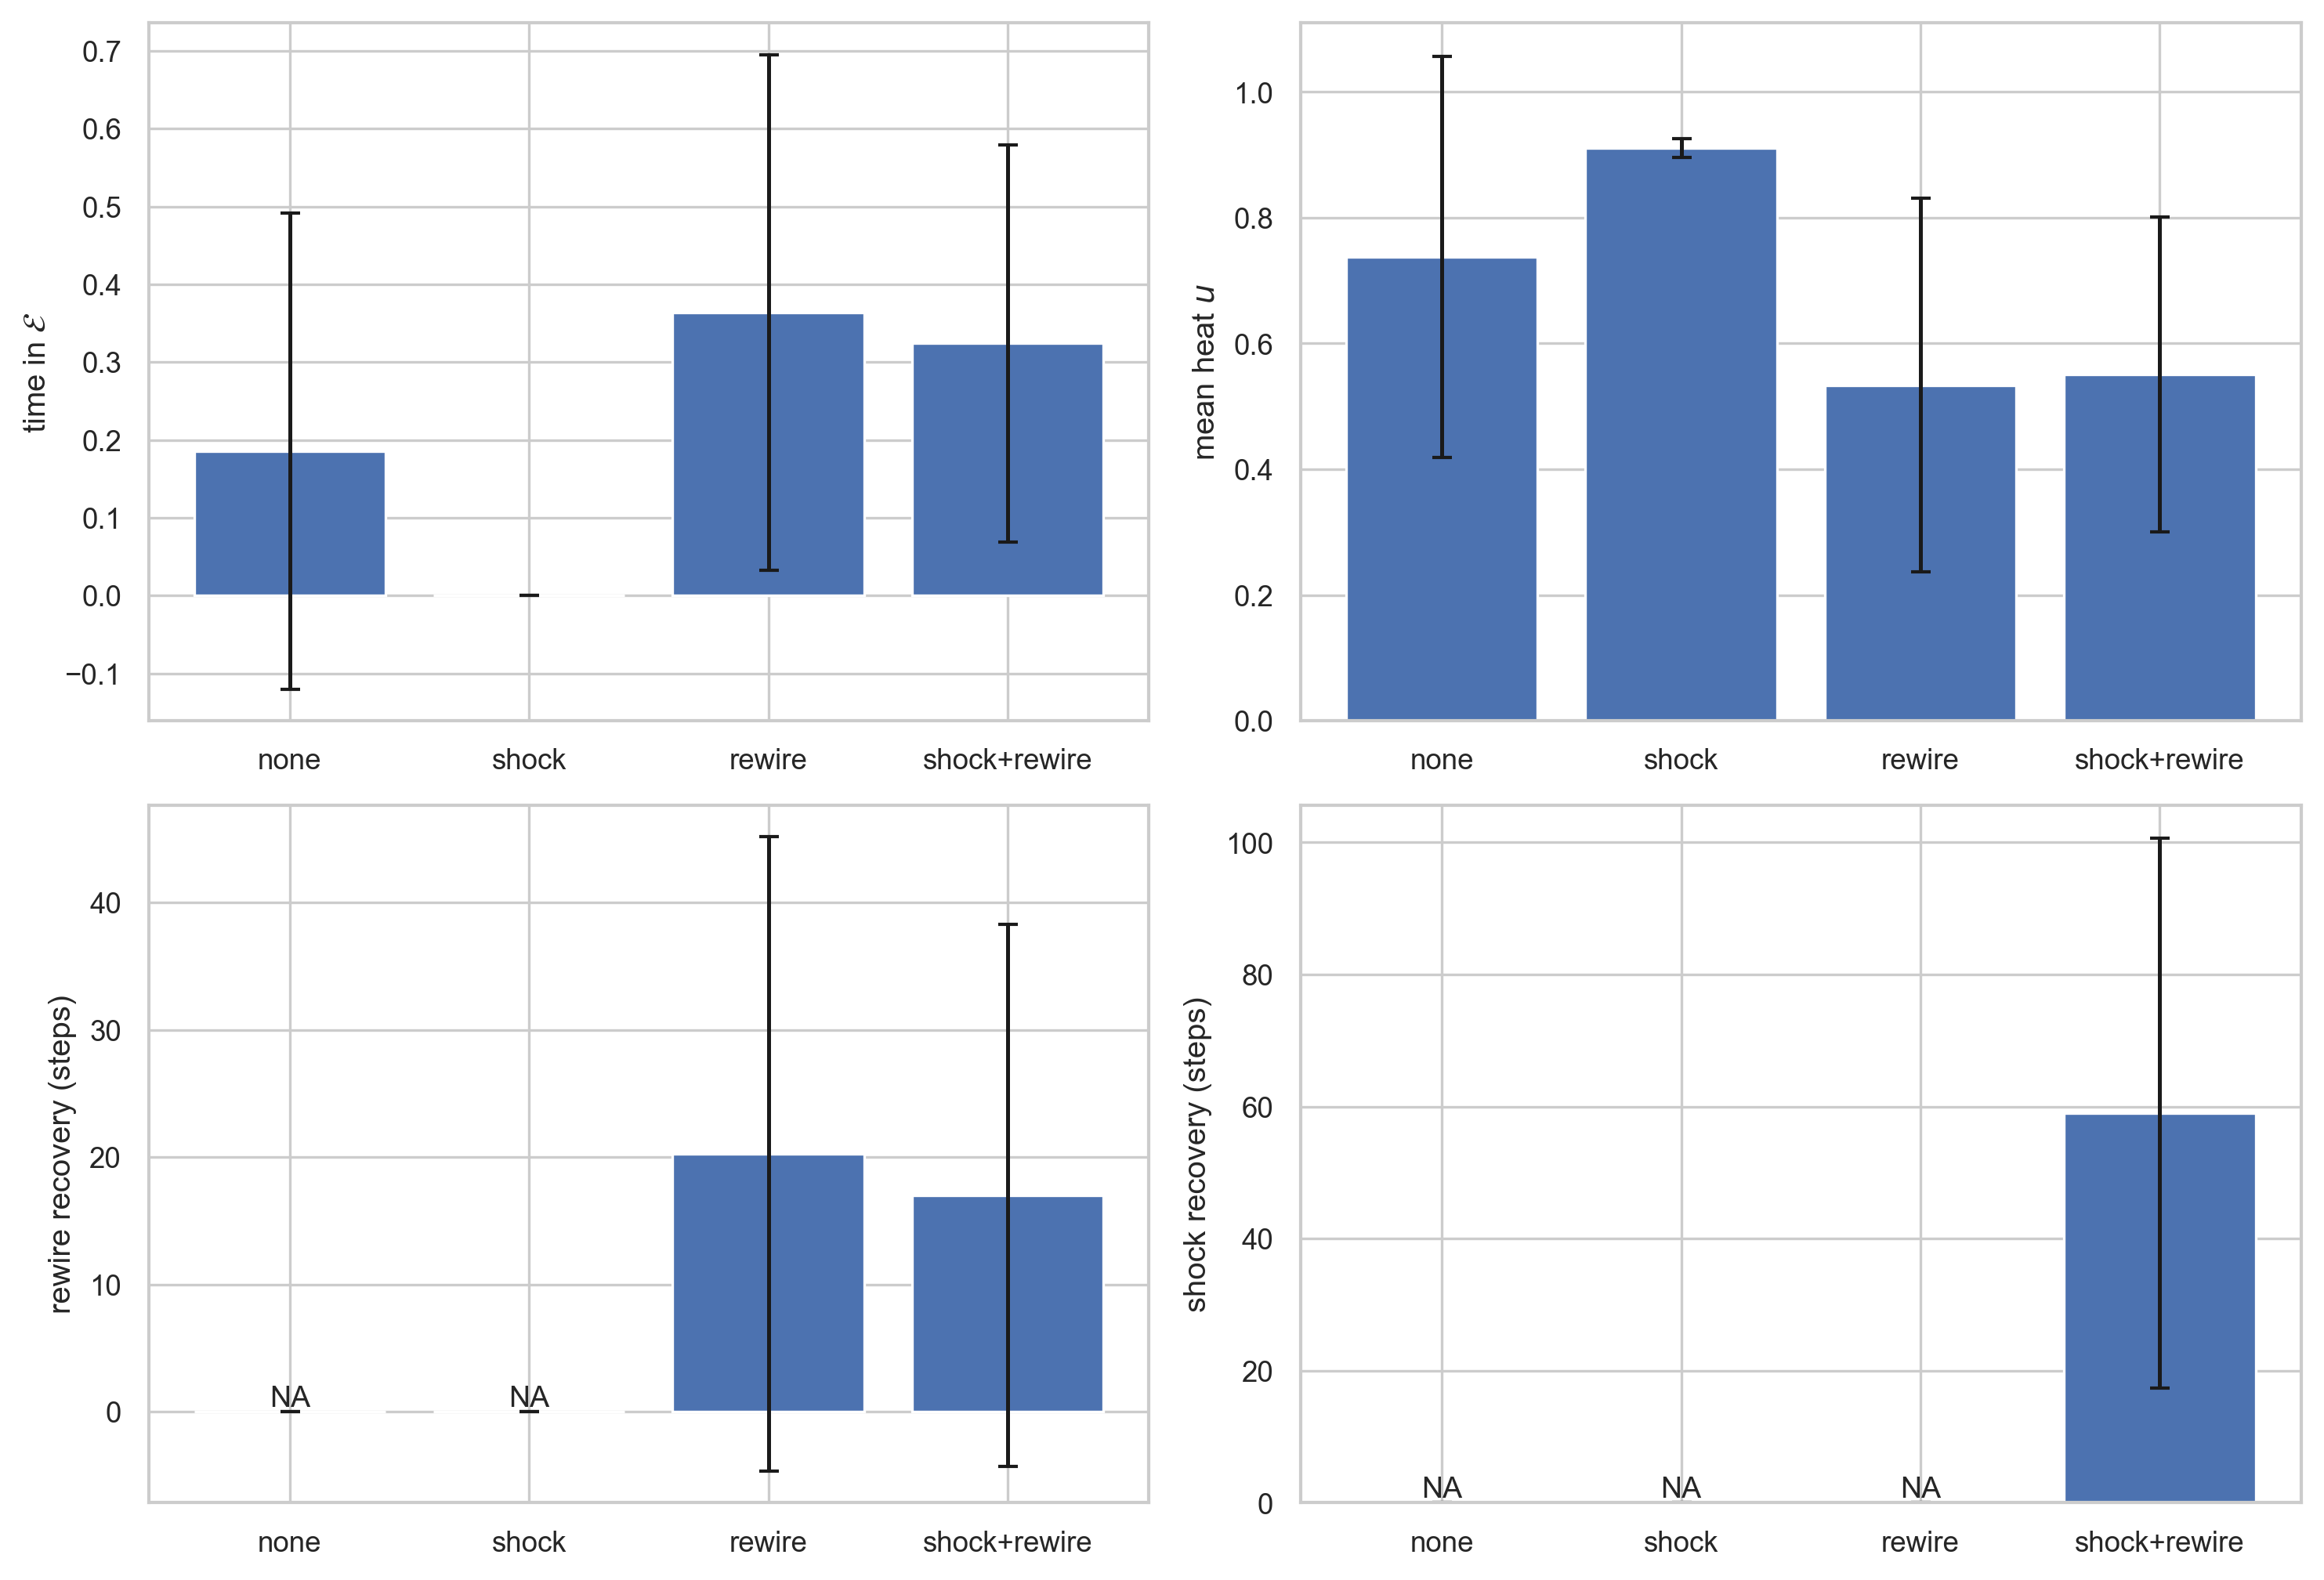
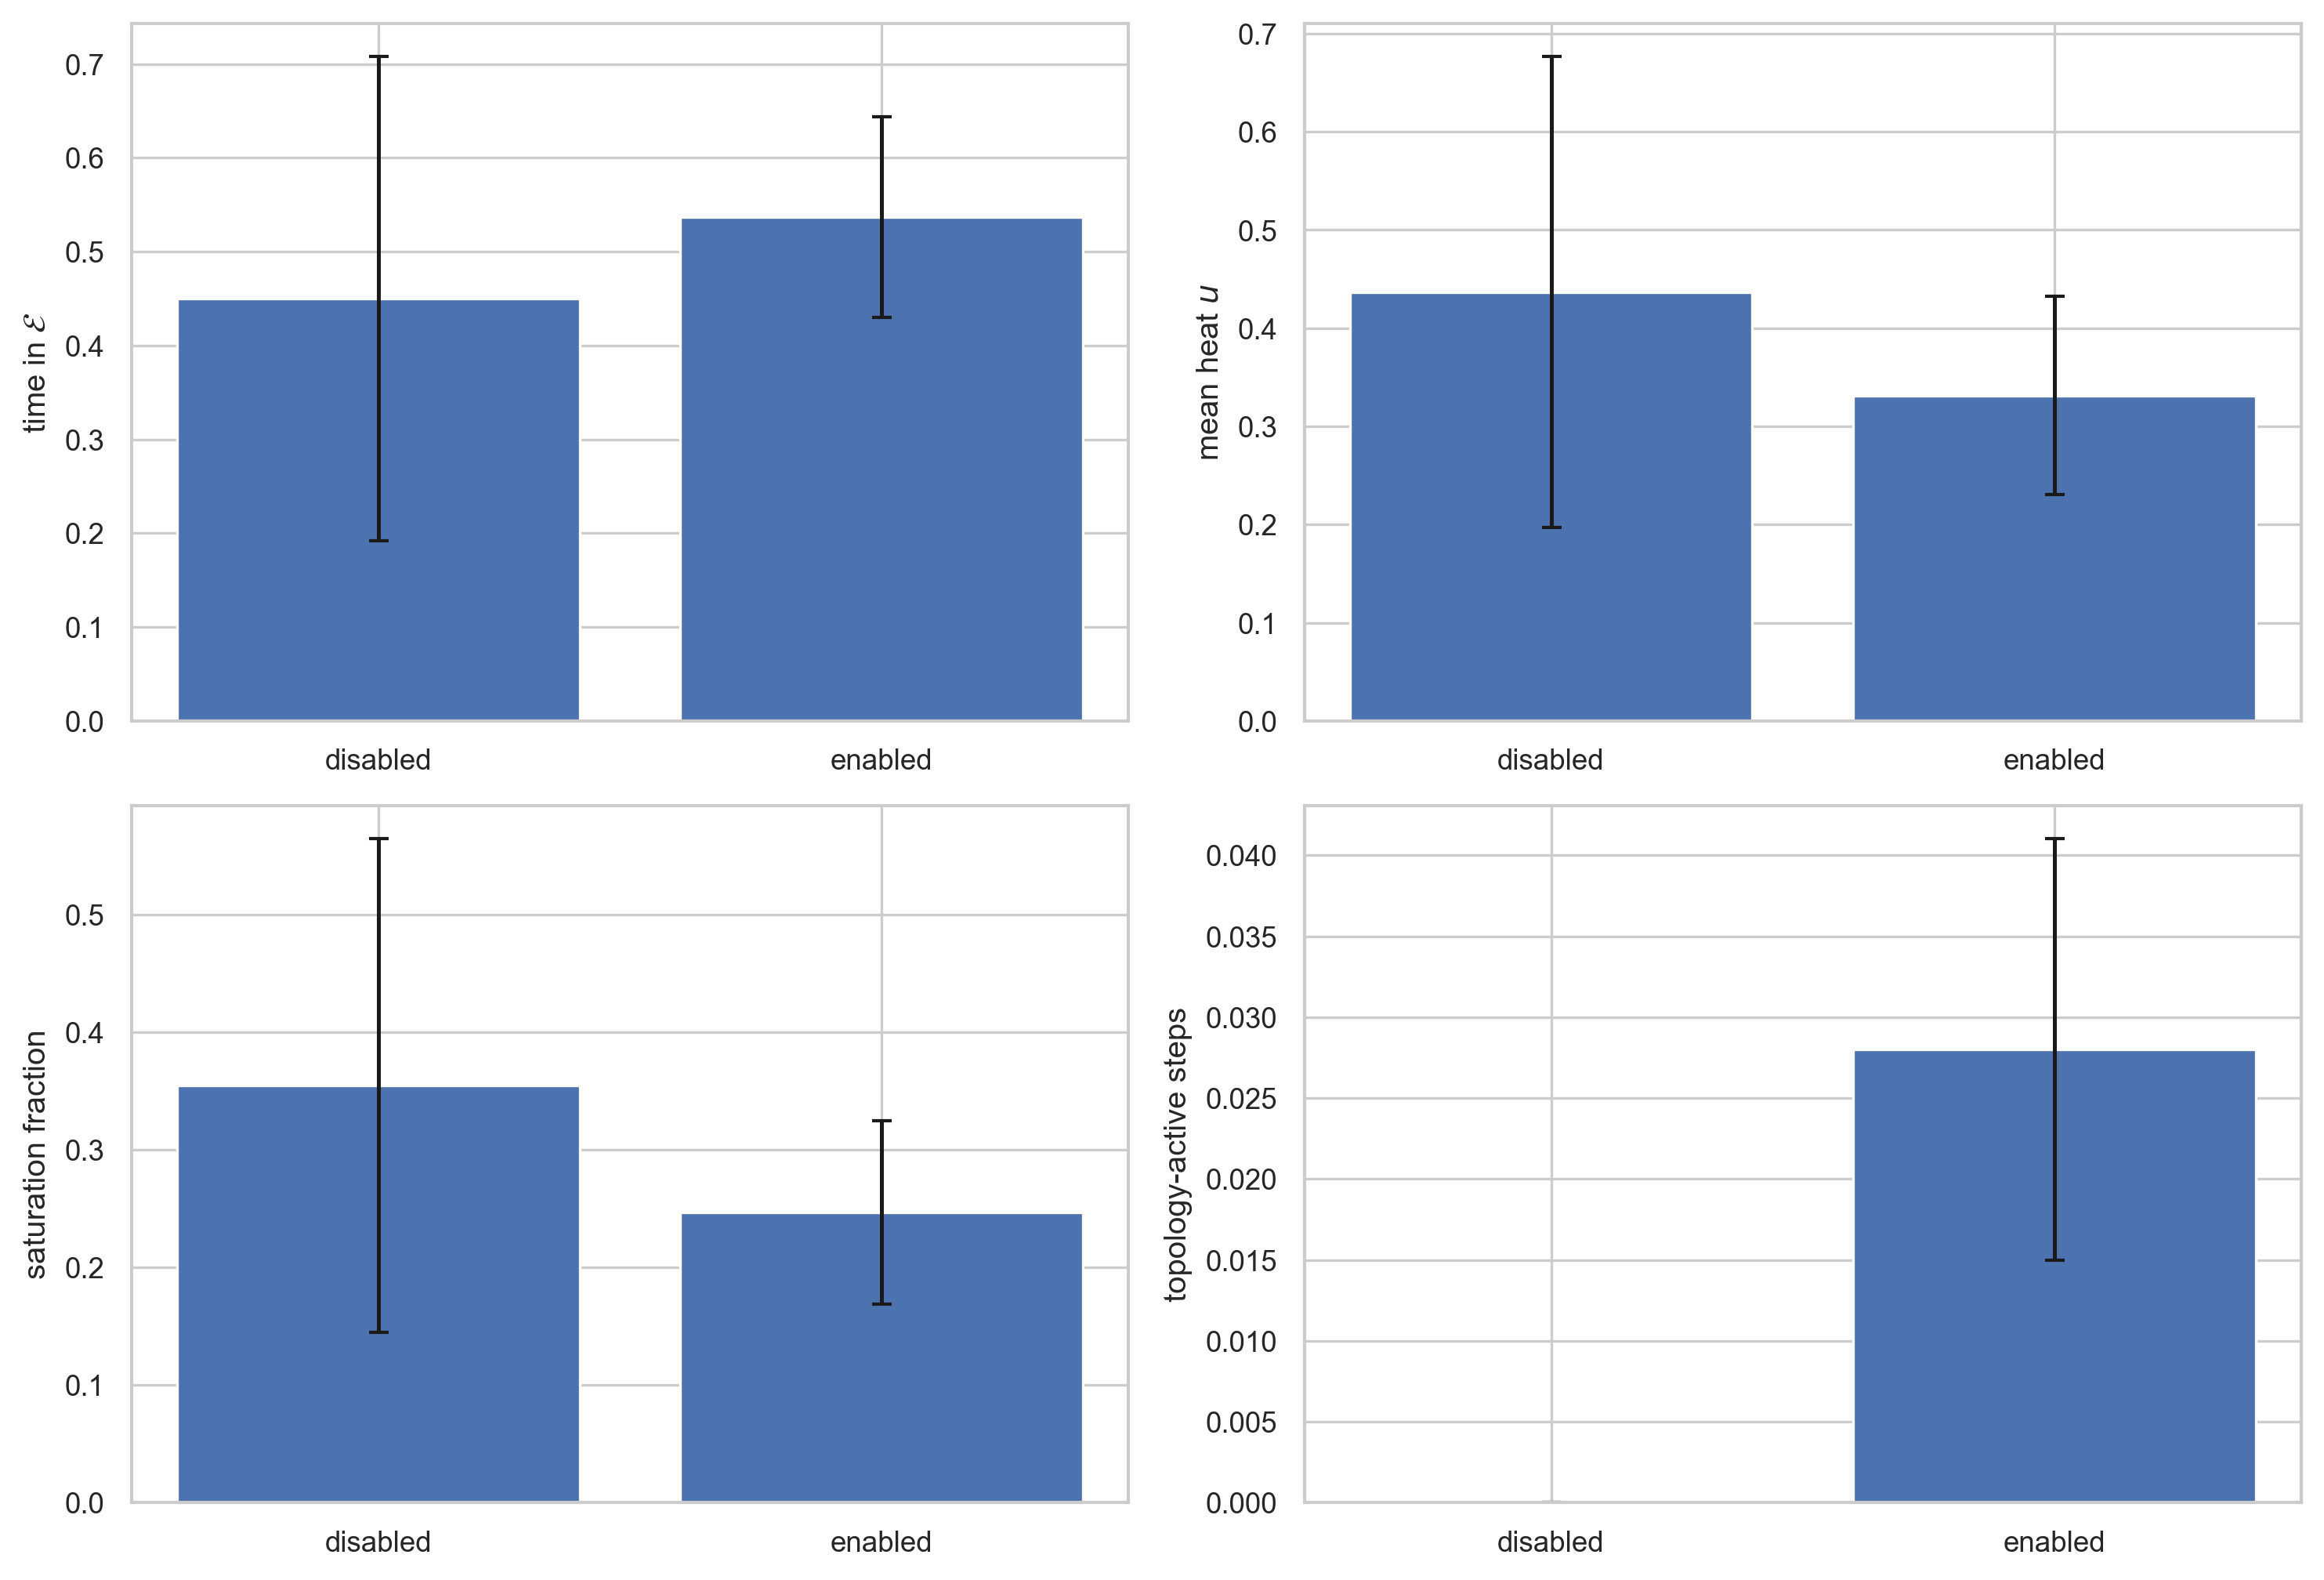
A closed-loop simulation study: a networked system of binary cooperation states is monitored through privacy-compatible aggregated edge-count observations only. A Bayesian detector keeps a Dirichlet belief over edge-type proportions with exponential forgetting, estimates coarse signals (cooperation, discord, entropy, volatility), and computes a posterior probability that a configured constraint set is satisfied. A smooth thermostat controller maps posterior risk to a single continuous actuation variable. Sweeps evaluated performance and belief calibration along an observability gradient (sampling rate, observation noise, aggregation level), plus stress ablations and a topology-actuation ablation.
What the author thinks about it now, and how the thinking evolved
I started this project wanting a grand framing: ethical states of complex networks as attractors, governance as steering a system into a basin. That framing outpaced the evidence. The work here never demonstrated attractors in any dynamical-systems sense. It defined a constraint region over coarse observables and drove a simulated system into it with feedback. That is control, not attractor discovery, and calling it attractors was branding. I am saying this plainly because the honest version of this project is more useful than the flattering one.
What survives the demotion is real, and it is the reason this archive exists. The architecture was always the point: monitor only what you can observe in aggregate, hold an explicit belief about whether the system is inside an acceptable region, act on that belief smoothly, and grade yourself against ground truth with calibration scores (Brier, log loss). That loop, evaluated honestly, is a decent instrument. The observability-gradient result, that monitoring quality bounds what governance can achieve at all, is the finding I still stand behind.
The flaws are on the record rather than buried: the paper under-described its strongest actuation lever (heat modulated the payoff structure itself, not just exploration noise), the sweep result CSVs behind the figures were never published alongside the code, replicates were thin, and one methodological description did not match the code. Each of these is fixable, and none of them is the reason this is suspended.
It is suspended because the next version does not belong in simulation. The observation architecture is most valuable pointed at real data: LLM-derived aggregate signals from real-world sources, feeding the same belief-state machinery, with calibration against human adjudication. That is what is being built at fact.ngo, as a fact-verification and data-integrity system. The successor work will be published there on its own merits.
The author, September 2026
Archive contents
- Code archive (README): simulation code, canonical config, figure scripts.
- Browse all files
- Download code.zip
- Published record (manuscript and versioned code): archived on Zenodo under its DOI. (DOI link: see the Zenodo record.)
The original GitHub repository hosting this code has been retired. This page is the maintained home of the code archive referenced by the published record.
Result figures (as published)
Licensing
Code is released under the MIT license (see LICENSE). Figures are part of the published record.
This page deliberately contains no author attribution. Authorship information is a permanent part of the Zenodo DOI record for this work.